
Calibration — External conveyor · Manual points
Calibration · External conveyor · Manual points
Use this method when the operator controls the conveyor externally and no calibration camera is installed.
An encoder connected to DeltaXStudio is required to measure conveyor position. Capturing robot points manually does not replace the encoder readings.
Required: robot + main camera + encoder. The operator starts and stops the belt externally; encoder feedback remains required.
Screenshots may show an earlier interface; use the field names in the instructions.
Configure this setup
Stop running tasks and keep Auto Start disabled. Check the robot and main camera connections. Confirm the encoder counts increase with forward conveyor travel.
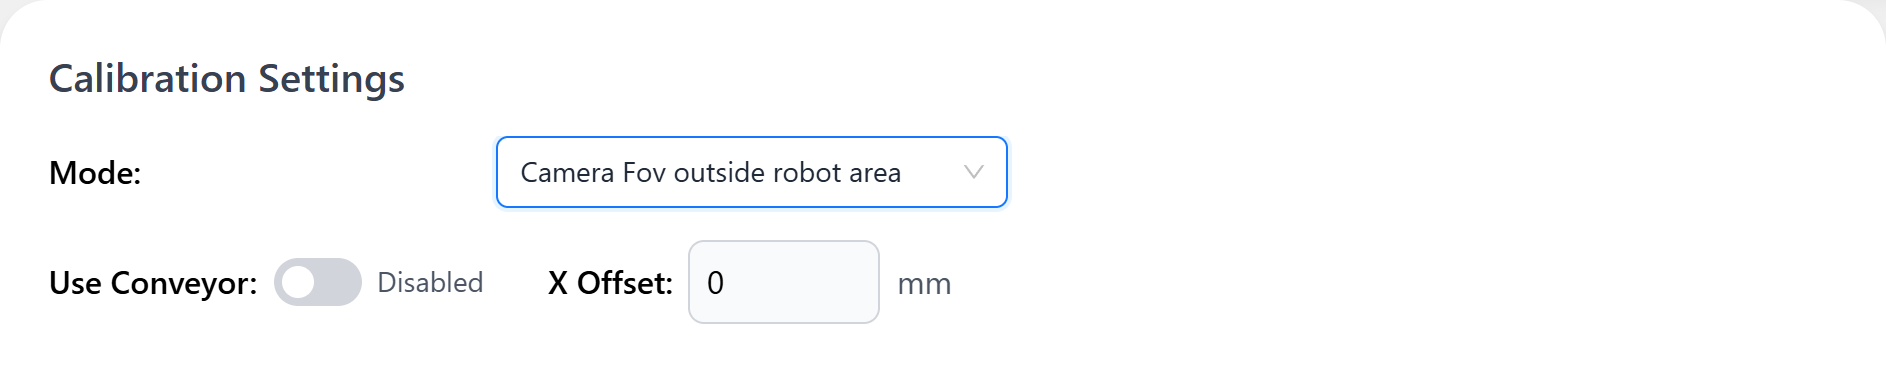
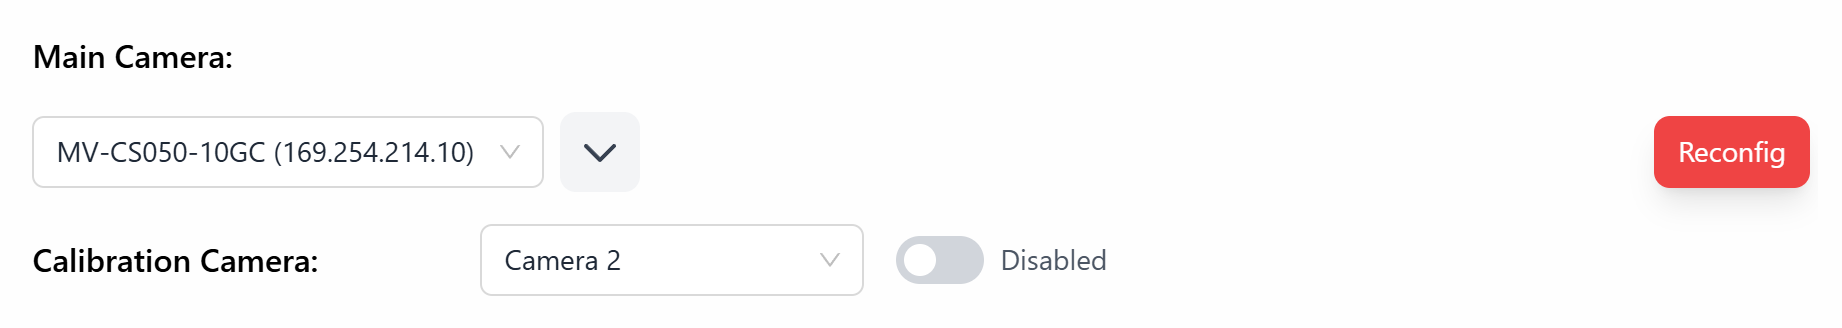
Disable Calibration Camera in Hardware Settings. Select Camera Fov outside robot area and disable Use Conveyor in Calibration Settings. Keep the encoder connected.
Check the working heights, save, reset, and wait for reconnection.
Check the working height
Open Settings → Parameters and select the intended robot if more than one is configured.
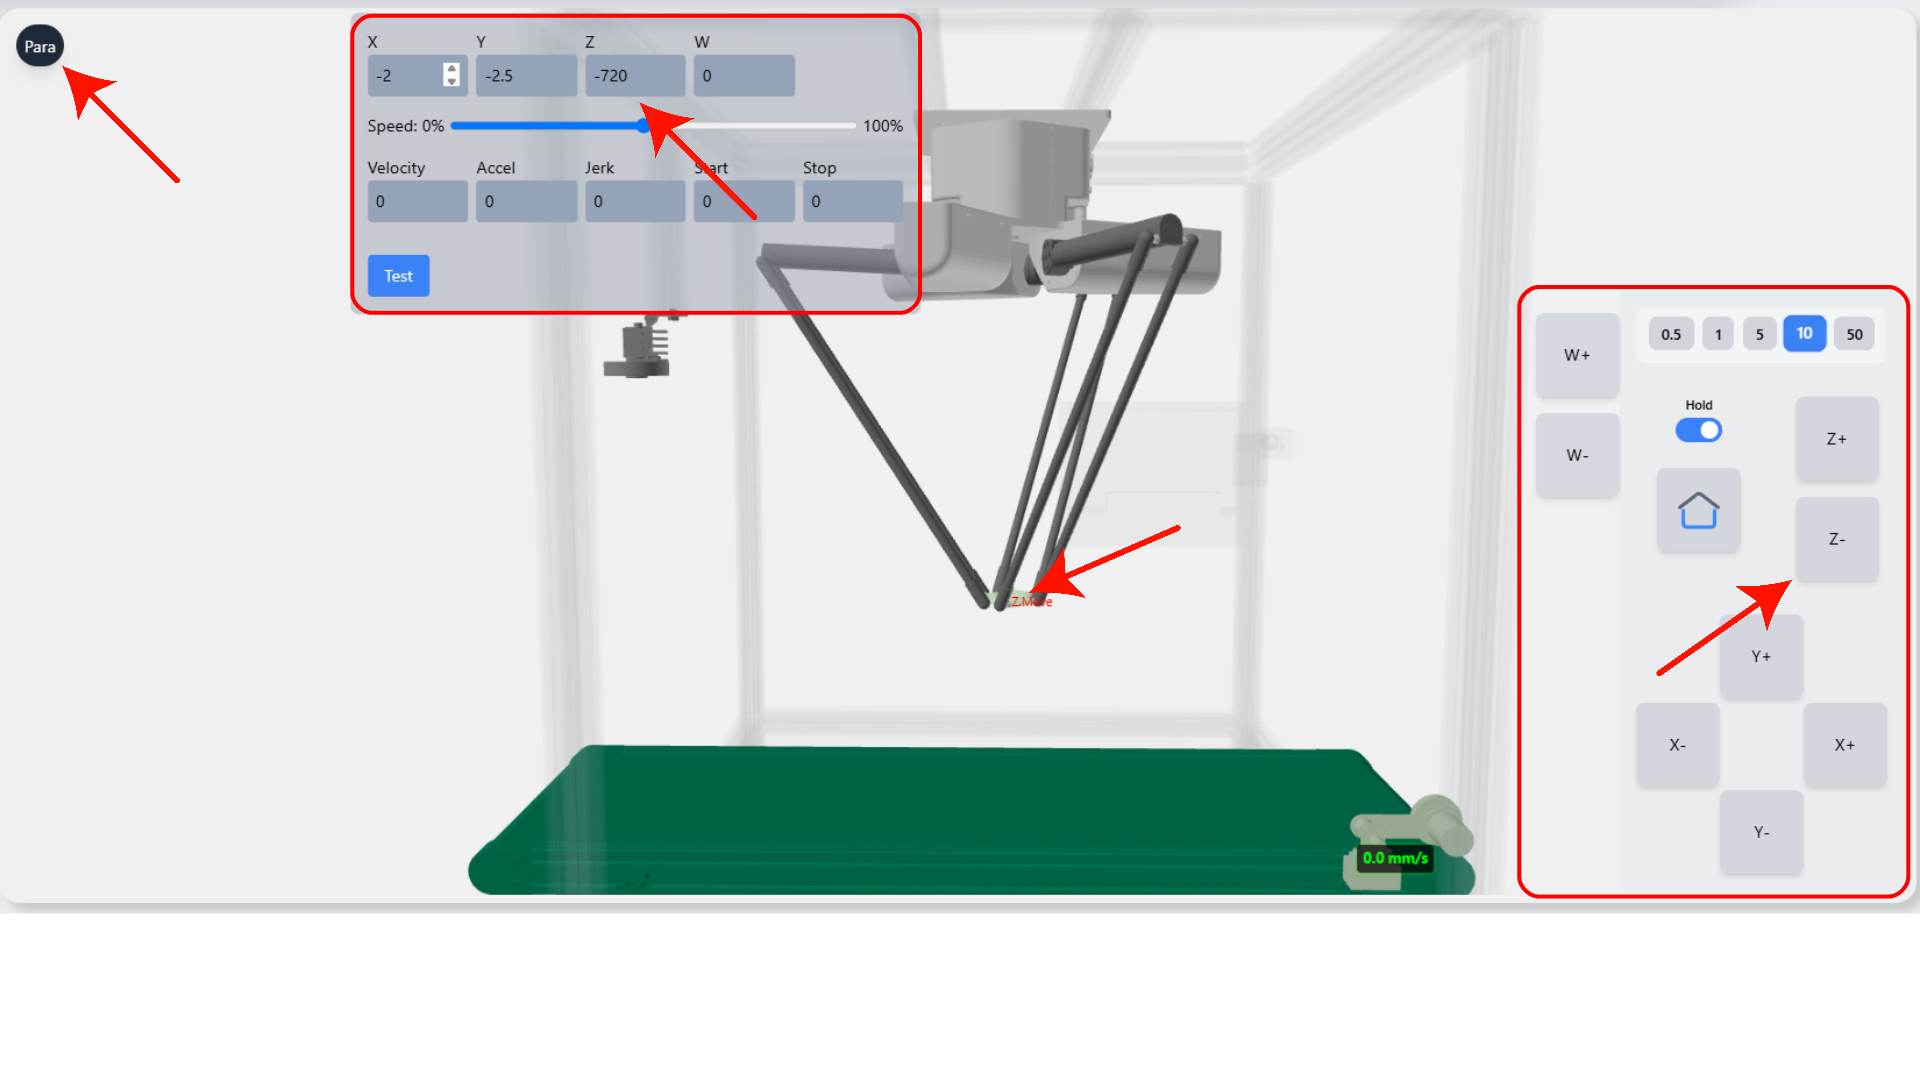
With the conveyor stopped, use the Dashboard robot controls to approach the belt surface with the installed tool. Reduce the jog increment near the surface and avoid pressing the tool into the belt. Read the robot’s Z coordinate at the belt surface and enter it in Other Parameters → Conveyor Z (mm). This is the field called Z Conveyor in the reference manual.
Set Travel Z (mm), called Z Move in the manual, to a height that clears the carried object, belt, fixtures, and destination throughout the transfer.
Save the settings before calibration. Automatic calibration uses Conveyor Z to calculate approach positions, so check this value for each configured robot.
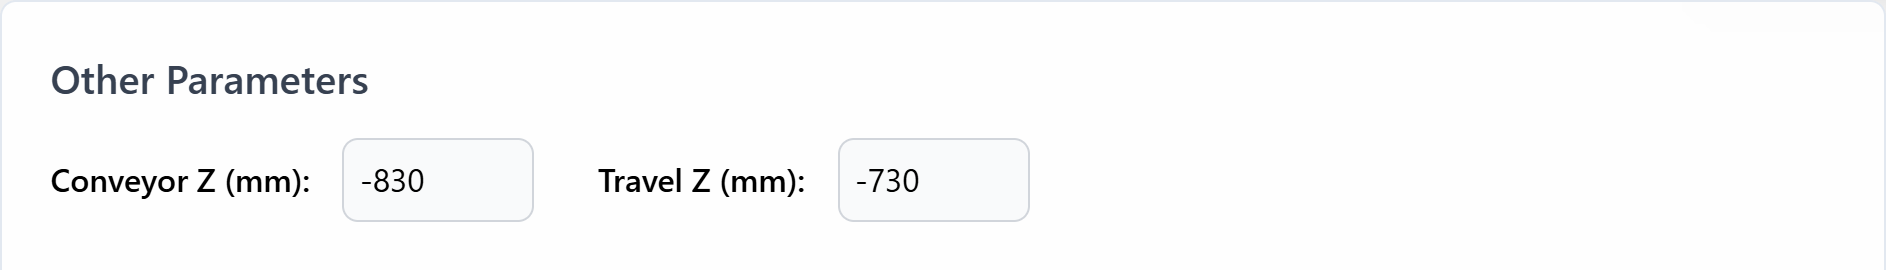
Three object heights above the belt can be used as an initial estimate for Travel Z. For example, a belt at Z = -740 mm and a 20 mm object gives -740 + 3 x 20 = -680 mm. Verify the actual clearance and robot reach; this estimate does not account for every tool or fixture.
If a jog command is rejected, check the displayed status, homing state, and configured travel limits before continuing.
Place the board and select the crop
Stop the conveyor and place the supplied board flat under the main camera. Align it with the belt and leave enough travel for the capture sequence. Check that the whole board is visible, sharp, and well lit.
Open Settings → Calibration and click Start. Follow any board-orientation guidance. Select two opposite corners of the detection area in the corrected image. Cover the useful conveyor area. Exclude blank image padding. Click Apply. The system is now ready to capture the reference points.
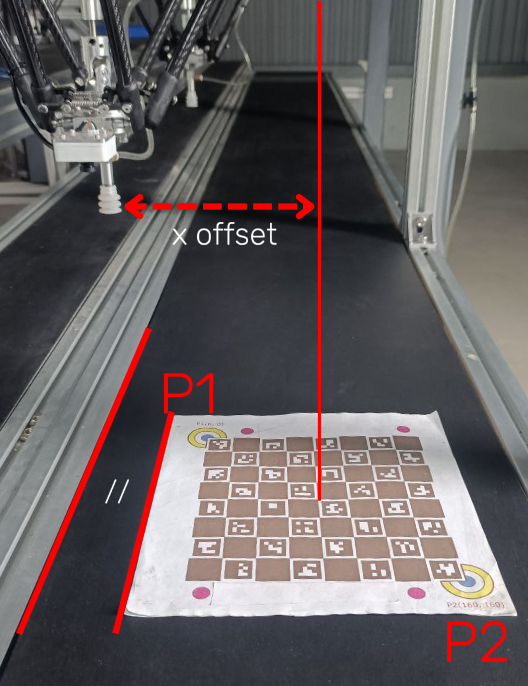
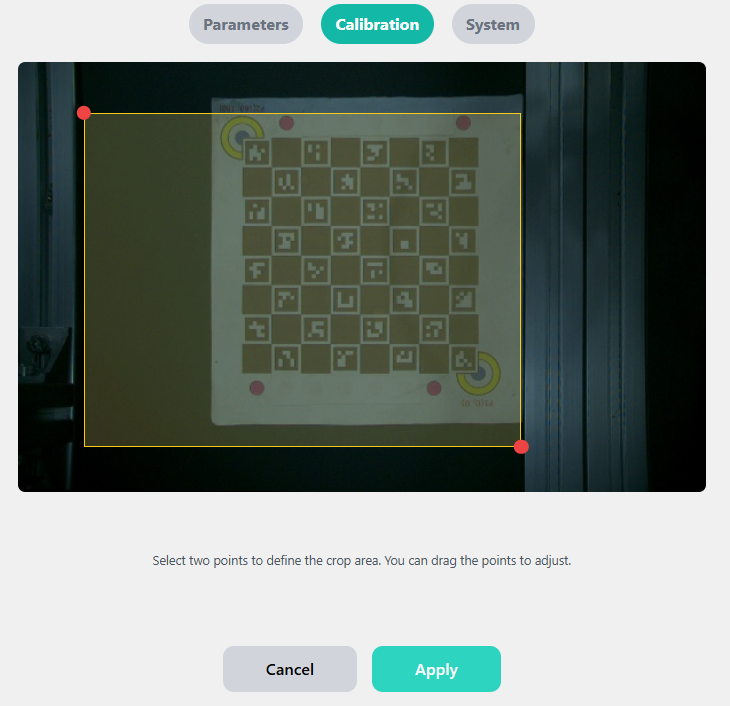
Let the conveyor carry the board between points. Do not lift, slide, or rotate it relative to the belt.
Capture the reference points
- Start and stop the belt using its own controls whenever the screen requests it. Use a low speed, approximately 20-30 mm/s, for these positioning steps.
- At Find Robot Point 1, follow the prompt to bring the board into reach, then stop the conveyor.
- Use the Dashboard robot controls to align the tool center directly above the board center without touching it. Wait for motion to finish and click Get Point.
- Move the conveyor again only when prompted. At Find Robot Point 2, stop the belt and align the robot with the board center at its new position.
- Capture the second point, repeat for any remaining robots, and wait for successful completion before clicking Done.
Both belt positioning and robot-point alignment are manual in this method. Keep the board fixed relative to the belt and capture each point only after the encoder readings are stable.
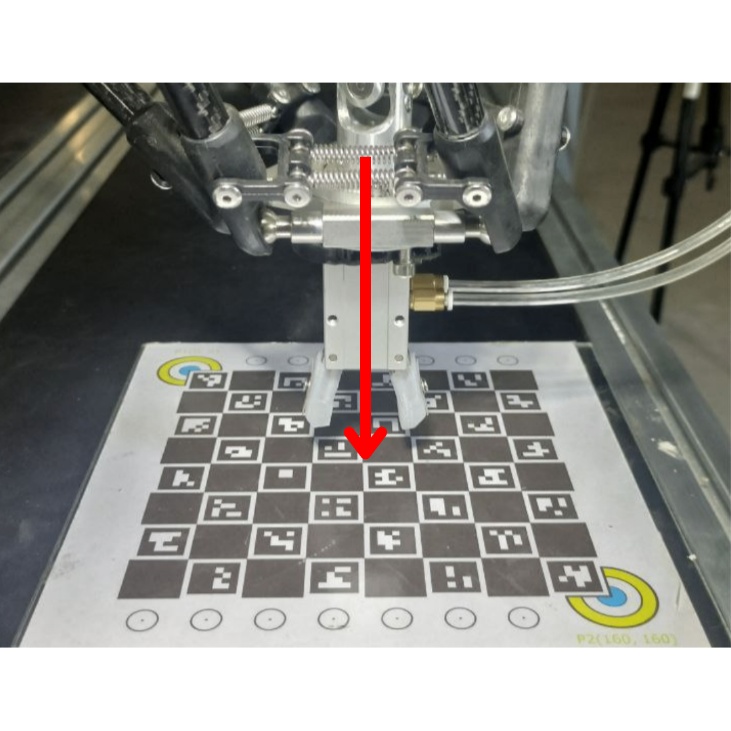
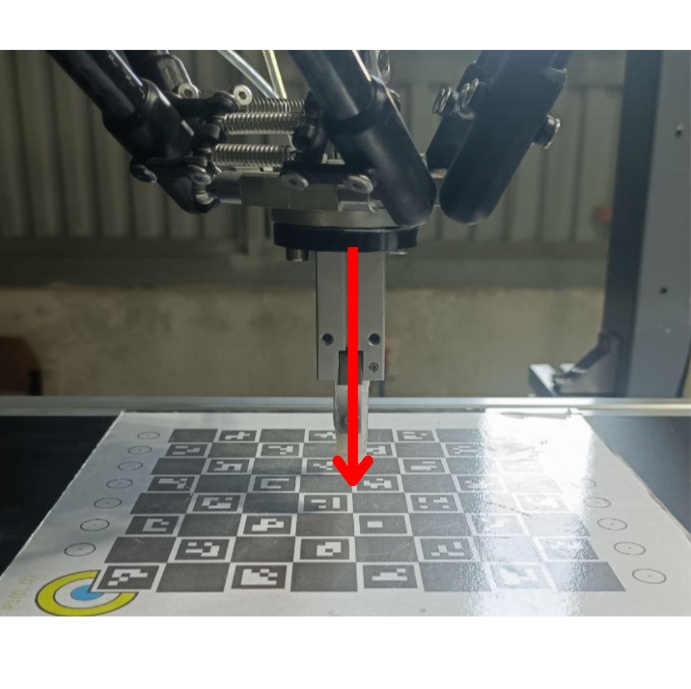
Confirm calibration
Wait for successful completion; the system validates and saves the reference points. Click Done, then check the corrected image and crop.
Continue to Vision to verify detection before the first pick. During the first low-speed picking test, check several object positions and conveyor tracking. Repeat calibration after moving the camera, robot, or conveyor relative to one another.
If this calibration cannot finish
| Symptom | What to check |
|---|---|
| Board not detected | Focus, lighting, board orientation, and complete board visibility. |
| Crop rejected | Select a non-empty area inside the valid corrected image. |
| Missing or reversed encoder feedback | Check the connection and counting direction. Encoder feedback is required for this method. |
| Board passes the capture area | Check available travel and camera-to-robot spacing. Reduce belt positioning speed and stop when prompted. |
| Get Point unavailable or rejected | Confirm a manual-point step is active, the robot is connected, and motion has finished with a stationary belt. |
| Browser reconnects | Wait for the current session state to reload before continuing. |
Use Stop or Cancel to end the workflow and wait for stopping to finish. Stop an external conveyor using its own controls. Calibration Stop waits for robot motion already in progress; use the physical emergency stop if immediate intervention is needed.