
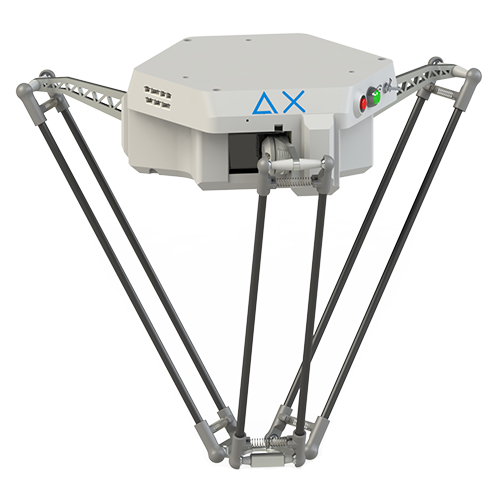
Delta X 2 Specifications
Basic Parameters
| Parameters | Specifications |
|---|---|
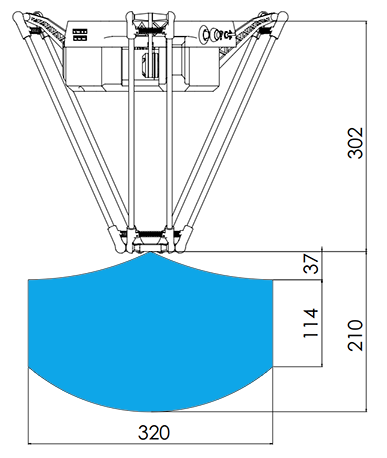
| Working space | D = 320 mm, H = 200mm |
| Max payload | 1kg |
| Max speed | 2000 mm/s |
| Max accel | 20000 mm/s2 |
| Pose repeatability | ±0.15 mm |
| Position accuracy | ±0.15 mm |
| Number of axes | 3/4/5 |
| Power supply | 12~24VDC - 5A |
| Weight | 4kg |
Electrical Parameters
| Components | Specifications |
|---|---|
| Controller Board | Delta X 2 Board (ARM Cortex-M7) |
| Communication | USB, UART, Ethernet |
| Input | 2 analog input/4 digital input |
| Output | 4 digital output (NPN) |
Mechanical materials
| Part | Materials |
|---|---|
| Upper Arm | Aluminum plate |
| Lower Arm | Carbon fibre tube |
| Base frame | Aluminum profile |
| Moving base | Aluminum |
| Motor mounted | Aluminum |
| Body cover | 3D printed (PLA) |
Robot Dimensions
Working Space
Safe Working Area
Moving Base Dimensions
Wiring and Pinout
Pinout
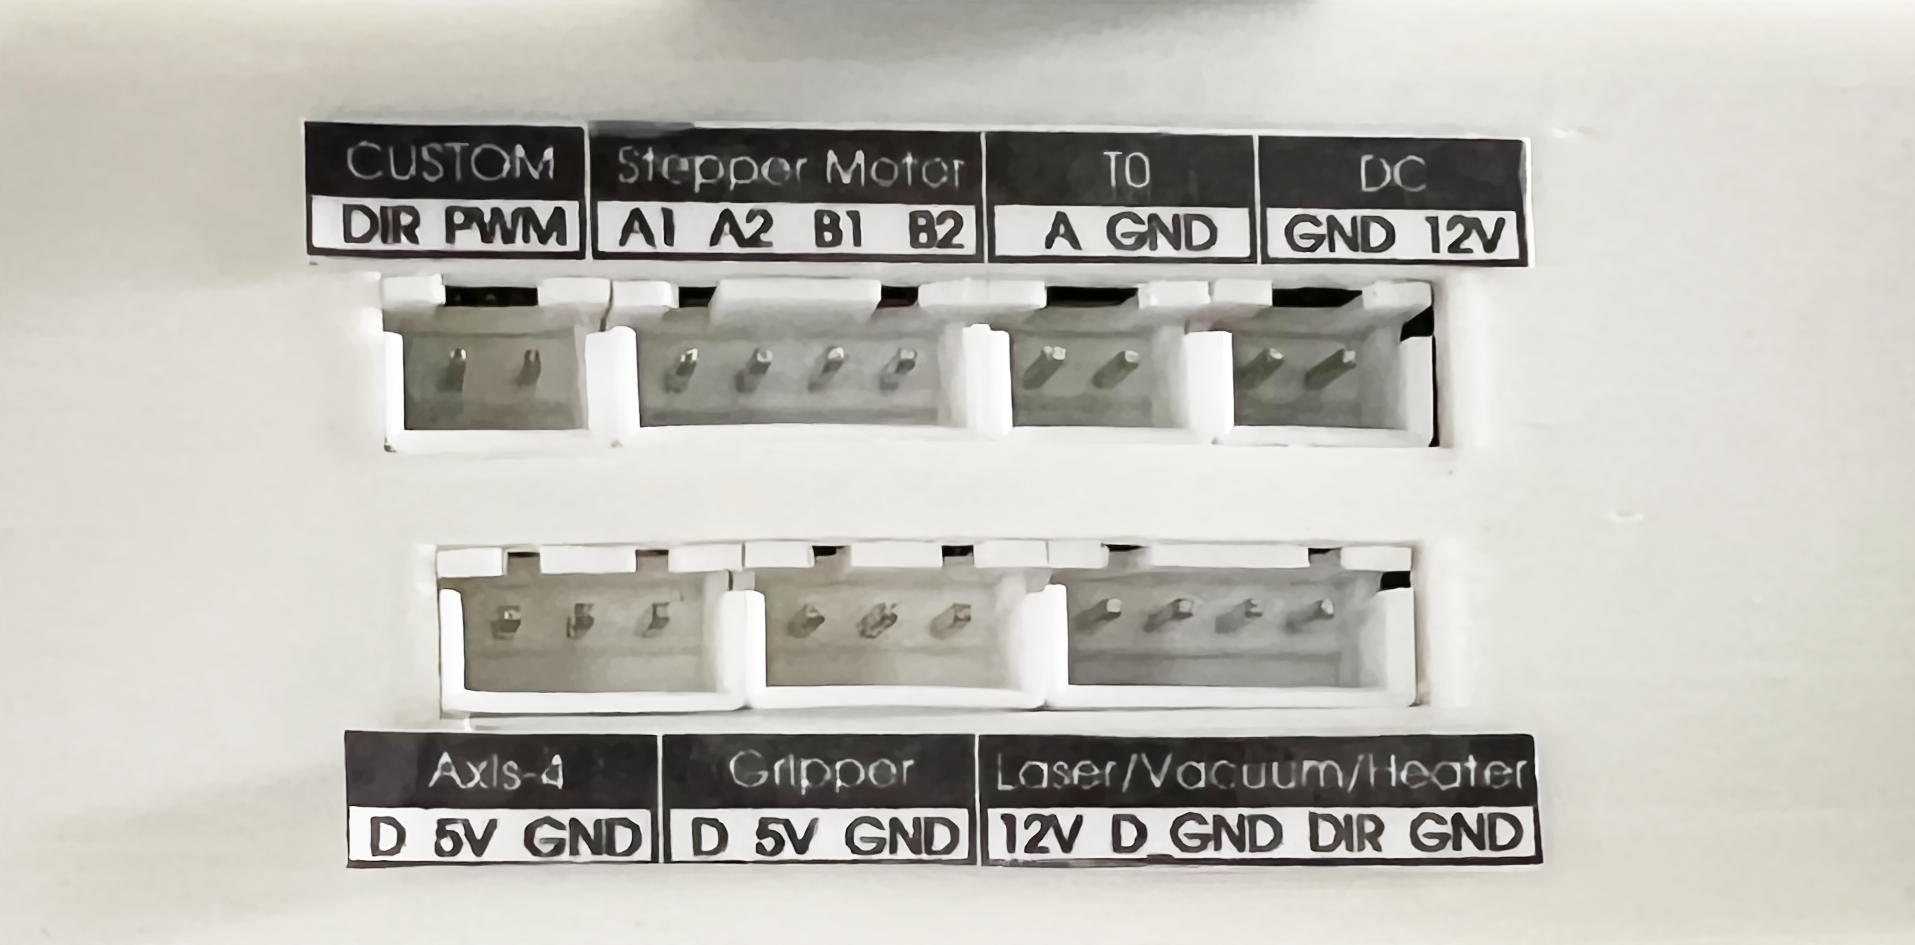
Delta X 2 Robot has multiple port for different end effectors. The port is located on a side of robot body. Includes:
- 1 Vacuum Port
- 1 Gripper Port
- 1 Axis 4 Port
- 1 Axis 5 Port
- 2 Analog Input Port
- 4 Digital Input Port
- 4 Digital Output Port
- 12VDC Power Supply Port
Communication Ports and Power Supply
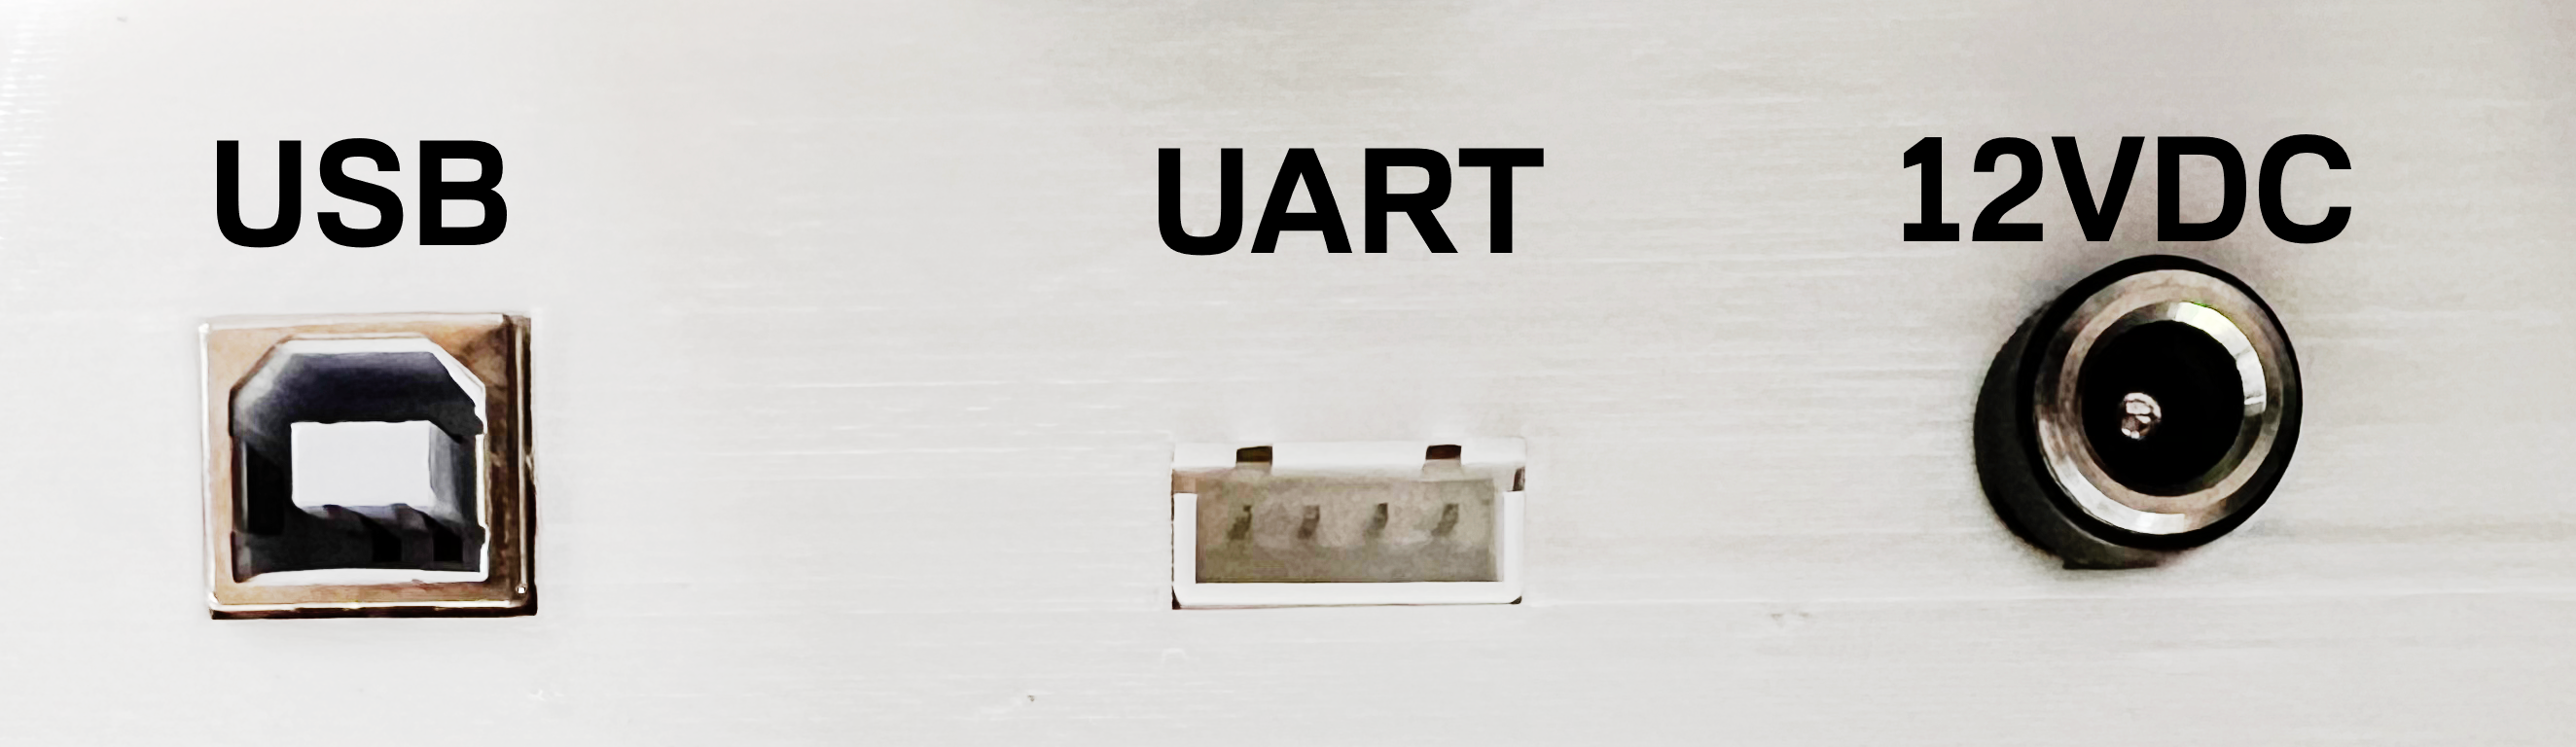
The robot has a USB-B port and a UART port for communication. The USB-B port is used for programming and debugging. The robot can be powered by a 12 ~ 24 VDC power supply with minimum 5A current.
Contact Us
- Store: https://deltaxstore.com
- Website: https://www.deltaxrobot.com
- Email: deltaxrobot@gmail.com
- Phone: +84 38 875 2005